CAN interfaces · Datasheet
SPI-CAN 40-pin Hat Rev A
CAN FD hat for 40-pin single-board computers
Features
- Standard 40-pin (2x20) GPIO header for direct mounting on Raspberry Pi and compatible SBCs
- SPI host interface for Classic CAN and CAN FD via the MCP2518FD controller
- Switch selectable bus termination (split 2x 60 Ohm + centre-tap capacitor)
- Jumper selectable silent mode (listen-only) for bus monitoring
- Operates at fixed 3.3 V logic
Overview
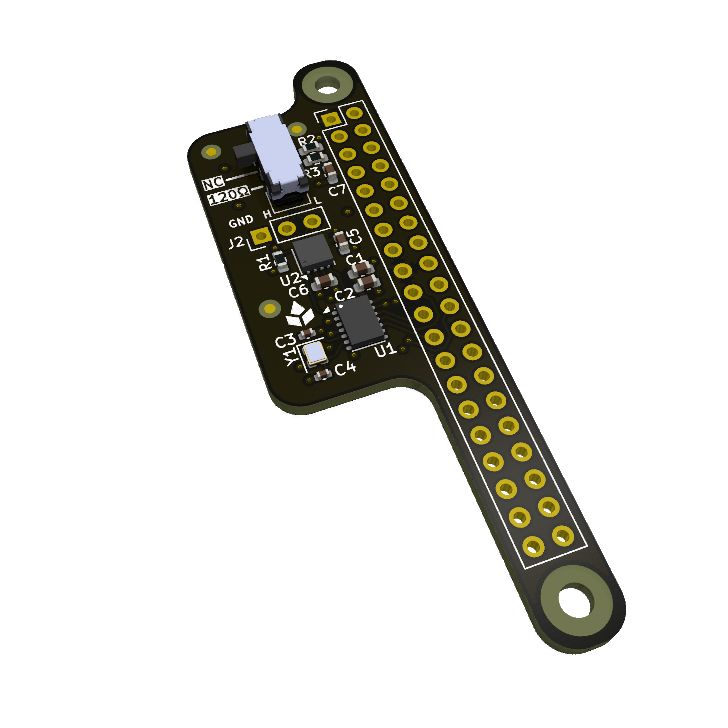
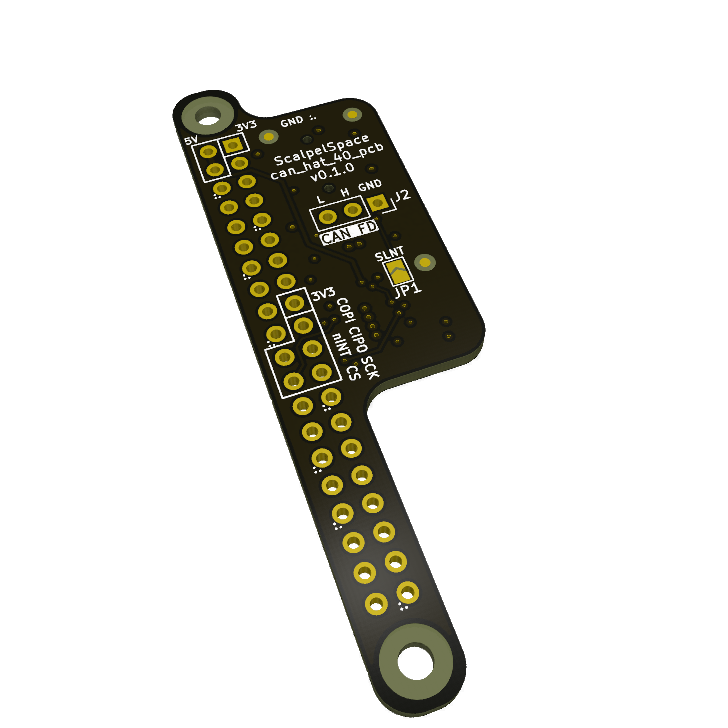
A 40-pin (2x20) GPIO hat that adds a CAN bus interface to single-board computers such as the Raspberry Pi series. It seats directly on the standard 40-pin header and bridges the host’s SPI bus to a CAN transceiver, so any compatible SBC can talk CAN without an integrated controller.
Specifications
| Parameter | Conditions | Min | Typ | Max | Unit |
|---|---|---|---|---|---|
| Power | |||||
| Supply | From the host 40-pin header | ||||
| Logic level | 3.3 V (fixed) | ||||
| Host interface | |||||
| Interface | SPI (default SPI0, CE0) | ||||
| CAN | |||||
| Controller | MCP2518FD, 40 MHz crystal | ||||
| Transceiver | TJA1057BTK | ||||
| Bus termination | Switch selectable 120 Ohm, split 2x 60 Ohm + centre-tap capacitor (SW1) | ||||
| Mechanical | |||||
| Form factor | 40-pin (2x20) GPIO hat | ||||
Connectors and pinout
| Ref | Connector | Description |
|---|---|---|
J1 | 40-pin | Standard 40-pin (2x20) GPIO pin header. |
J2 | CAN | CAN bus connection. |
J2: CAN
| Pin | Name | Type | Description |
|---|---|---|---|
1 | GND | PWR | Ground |
2 | CANH | IO | CAN high |
3 | CANL | IO | CAN low |
Switches and jumpers
| Ref | Function | Settings |
|---|---|---|
SW1 | CAN termination | 1 + 2 = 120 Ohm termination, 2 + 3 = no termination |
JP1 | CAN silent | Open = normal operation, closed = silent mode |
Detailed description
Host interface
The hat bridges the host’s SPI bus to the CAN bus through the MCP2518FD controller. By default it uses the host’s SPI0 bus (CE0) with the controller interrupt on GPIO22, which matches the device-tree overlay shown in the Linux setup guide.
The board operates at fixed 3.3 V logic.
Bus termination
The CAN termination switch (SW1) connects a 120 Ohm split termination (2x 60 Ohm with a centre-tap capacitor) across the bus. The switch positions are marked 120 (terminated) and NC (not terminated).
Enable termination only when the board sits at a physical end of the bus.
Silent mode
Closing the CAN silent jumper (JP1) puts the transceiver in silent (listen-only) mode, for monitoring a bus without transmitting on it.
Key components
| Part number | Manufacturer | Description | Qty |
|---|---|---|---|
MCP2518FDT-E/QBB | Microchip Technology | CAN FD to SPI controller | 1 |
TJA1057BTK | NXP USA Inc. | CAN bus transceiver | 1 |
JS202011JAQN | C&K | DPDT slide switch, right angle | 1 |
ECS-400-10-37B2-CKY-TR | ECS Inc. | 40 MHz crystal | 1 |
Mechanical
Design files
Errata
No known errata for Rev A.
Revision history
| Revision | Released | Status | Changes |
|---|---|---|---|
| Rev A | 2025-08-03 | Active |
|